A startup built on a lab thesis
Nanjing’s Coolink Robotics has just closed a tens-of-millions-of-yuan angel round, led exclusively by the Nanjing Liuhe economic-development industrial investment fund managed by Bailian Zhigao. The company, founded in 2025, will put the money into research on joint modules and joint thermal-management systems for humanoids and robot dogs, and into expanding capacity.
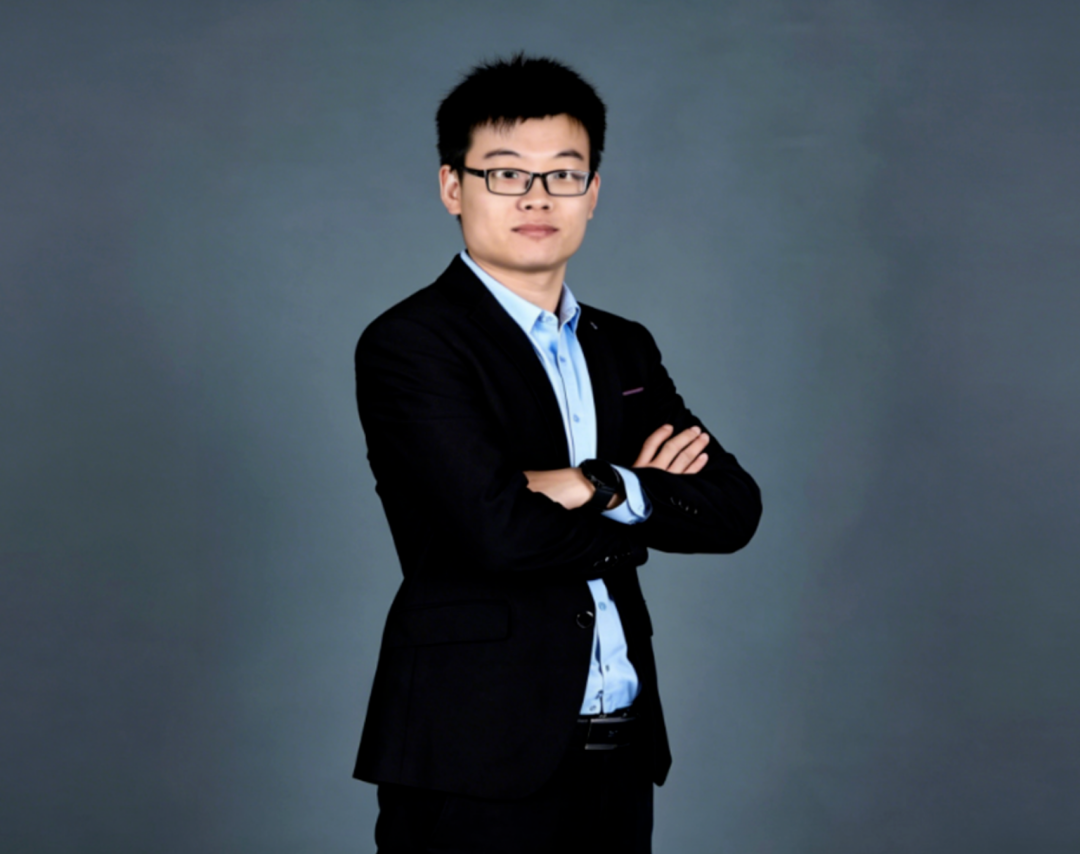
The founder, Yuan Yanjie, is also an associate professor at the College of Mechanical and Electrical Engineering of Nanjing University of Aeronautics and Astronautics and a Jiangsu “dual-innovation” doctorate with overseas joint-training experience. He has long studied the basic research behind integrated robot joints, and his move from the lab to the startup front line reflects the real opportunity and the real test facing China’s domestic robot-components track.
Why joints overheat
Many observers lazily tag university-born projects as “lab technology” and worry the research will never cross the mass-production gap. From the start, Coolink aimed at the full self-developed system of integrated joints, covering high-torque-density motors, lightweight reducers, servo drives and smart controllers, rather than supplying a single part.
The company has already launched seven joint-module products built on self-developed efficient thermal management. In July it said the high-efficiency thermal-management integrated joint module would soon reach batch production and market delivery, already deployed across quadruped, humanoid and collaborative-robot scenarios.
The reason thermal management became a startup’s wedge is a hidden pain the industry had already spotted. When a humanoid walks or runs for long stretches, the joint motor runs under constant high load, heat builds fast in a tight sealed space, and excessive temperature brings permanent-magnet demagnetisation, falling control accuracy and, in the worst case, a full machine stop. Plenty of prototypes fail long endurance tests precisely on cooling.
The component layer is where the money goes
The industry had fixated on torque and weight, leaving thermal management an overlooked bottleneck. Off-the-shelf cooling parts do not fit a joint’s compact cavity, and bolting on external components wrecks the integration. That forces makers to co-design motor, transmission and cooling instead of assembling purchased parts. Rivals are trying liquid cooling and phase-change materials, each hunting the balance of size, power and cost.
There is a wider point. Humanoid whole-machine makers all want a self-reliant supply chain, and joint modules take close to half of the hardware cost. The market needs both the big mature suppliers and a batch of focused startups with differentiated routes, giving whole-machine makers more choice.
The caveat is real. Prototype success is not stable mass production. Dozens of precision parts assembled under volume manufacturing meet yield, consistency and cost hurdles, and many projects stall at the sample-to-product stage. Coolink must still prove its thermal joints hold up under repeated shock and that batch delivery lands inside the price band downstream makers will accept. Tens of millions of yuan is a starting line, not a finish.
Editor’s note: This is an adapted translation of the original OFweek Robotics report. It has been trimmed and restructured for readability for an international business audience. The full original (in Chinese) is at https://robot.ofweek.com/2026-10/ART-8321201-8420-30706319.html.