D-Robotics, a Shenzhen-based robotics company, has released WM-LOCO, a system for humanoid robots walking over complex terrain. The company says it is the first to jointly train a predictive world model and a PPO reinforcement-learning policy end to end.
The aim is to improve continuous walking and decision-making when foot placement is constrained. The company demonstrated the system live on its Sunrise S600 computing platform, and has published the technical paper and project homepage.
From pixels to joint commands
WM-LOCO does not rely on footstep annotation, teacher distillation or a serial multi-module pipeline. It trains in one step from visual input to joint control commands. Its recurrent world model combines onboard depth images, body perception and action history, and learns how actions affect future body state and visual observation.
The predictive internal features formed by the world model feed directly into control, letting the walking policy coordinate body motion and foot placement. There is no need to unroll a multi-step future prediction and then search for an optimal plan. Under the same sensing input and training budget, adding the world model sharply improved passage through stepstones, gullies and narrow beams.
From simulation to a real Unitree G1
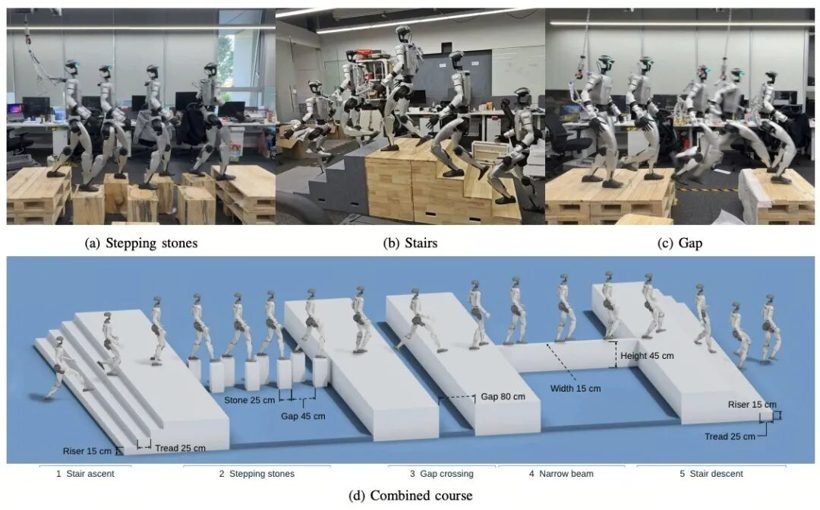
In simulation, the robot faced four discrete sparse terrains, stepstones, stairs, gullies and a narrow beam, and passed close to one hundred per cent of trials. The same trained weights were deployed zero-shot onto a real Unitree G1. Across four terrain types with ten tests each, overall success reached 92.5 per cent, including crossing a gap eighty centimetres wide and walking along a beam ten centimetres wide.
The live demonstration on the Sunrise S600 platform was designed to show the algorithm holds up under real sensor noise and physical conditions. For Shenzhen’s robotics scene, the result is a small but concrete step: a world model trained in simulation transferring to a real machine without retraining, on terrain that would defeat a conventional gait controller.
Editor’s note: This is an adapted translation of the original Gasgoo report. It has been trimmed and restructured for readability for an international business audience. The full original (in Chinese) is at https://www.gasgoo.com/robot/news/70478471-%E5%9C%B0%E7%93%9C%E6%9C%BA%E5%99%A8%E4%BA%BA%E6%8E%A8%E5%87%BAwm-loco%E6%96%B9%E6%A1%88/.