Orbbec and Daxiao Robotics, together with its partners, have signed a 10,000-unit strategic procurement agreement covering depth cameras, RGB cameras and body-free data capture hardware, with first deliveries already under way.
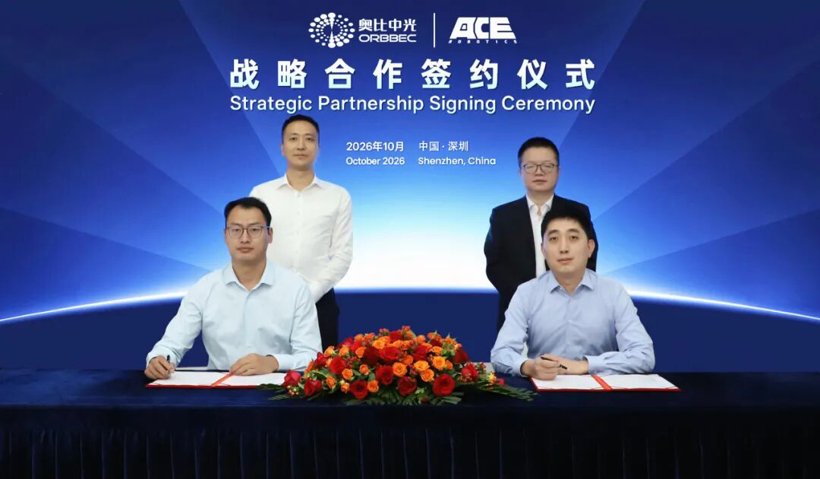
The scope goes beyond sensors. Orbbec will supply software adaptation, customisation and volume manufacturing support alongside the hardware, and the two companies will work on making the vision stack used for data capture structurally identical to the one fitted to the robot itself.
The capture rig is the model’s blind spot
The goal is a common visual representation between the point where data is collected and the point where it is used. In practice that means the images a dataset is built from should look like the images the deployed robot will see, including viewpoint, lens geometry and lighting conditions.
Much of the recent embodied data in China has been gathered with handheld and body-free rigs, which are cheap and fast but produce a viewing geometry that a robot’s head-mounted cameras do not reproduce. Closing that gap is a hardware problem before it is a training problem.
Orbbec has built its capture line around that assumption, with an EGO first-person platform, a UMI handheld manipulation rig, WristCam for close-range work and a Hub synchronisation unit. The company positions itself as the hardware base layer for physical AI data collection, offering standard products alongside custom, CM and JDM arrangements.
Daxiao supplies the model and deployment side. Its Kairos 3.1 world model is described as the first open-source model of its kind in China to reach commercial application, and the company has shipped industry packages for hotel, retail and inspection scenarios.
The devices will serve both Daxiao’s robot bodies and its environmental capture system, supporting multi-view real interaction recording as training input. The two companies had already worked together on robot vision, with Orbbec depth cameras used in Daxiao projects, and this agreement extends the relationship from perception hardware into data acquisition.
Editor’s note: This is an adapted translation of the original Gasgoo report. It has been trimmed and restructured for readability for an international business audience. The full original (in Chinese) is at https://auto.gasgoo.com/news/202610/30I70476375C601.shtml.