RoboHarness: When One Robot Brain Is Not Enough
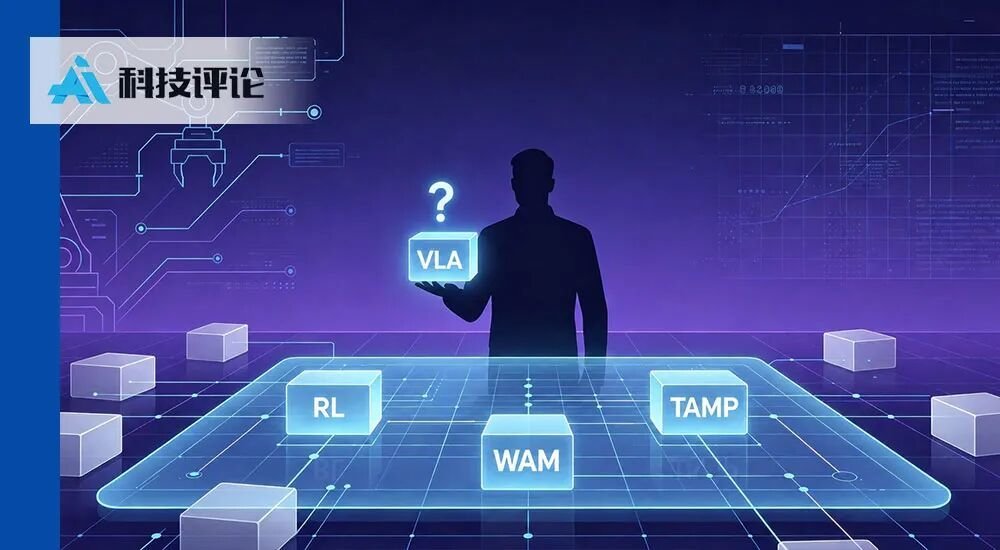
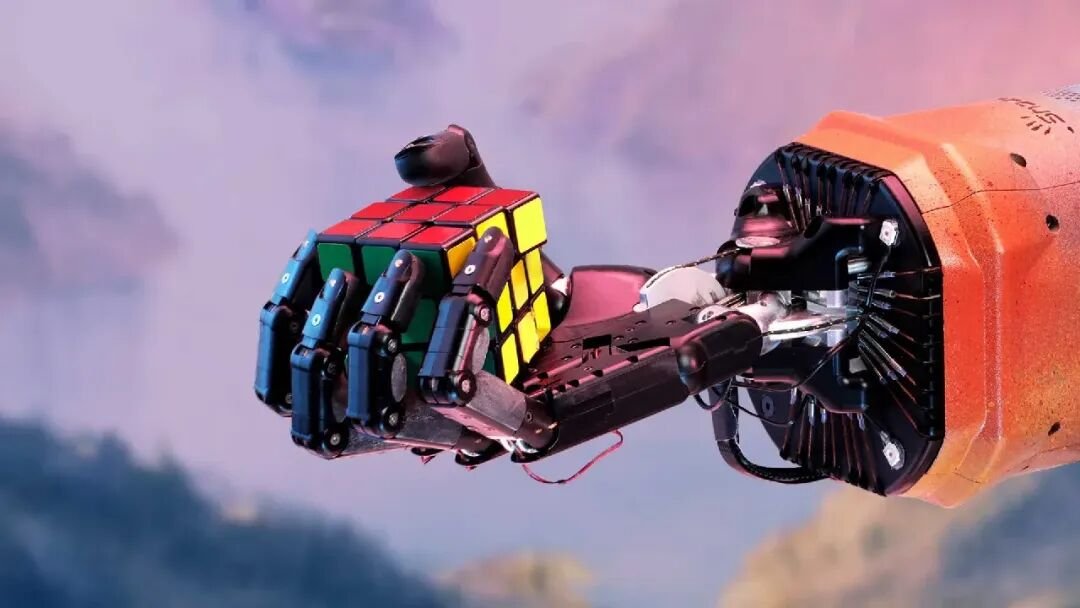
Open a cupboard, find the blocks hidden inside, then stack them into a bridge. A child manages it. For a robot the task splits into capabilities that live in different models: vision and language following to find the blocks, contact-rich interaction to open the door, geometric planning and fine control to build the span. Vision-language-action … Read more