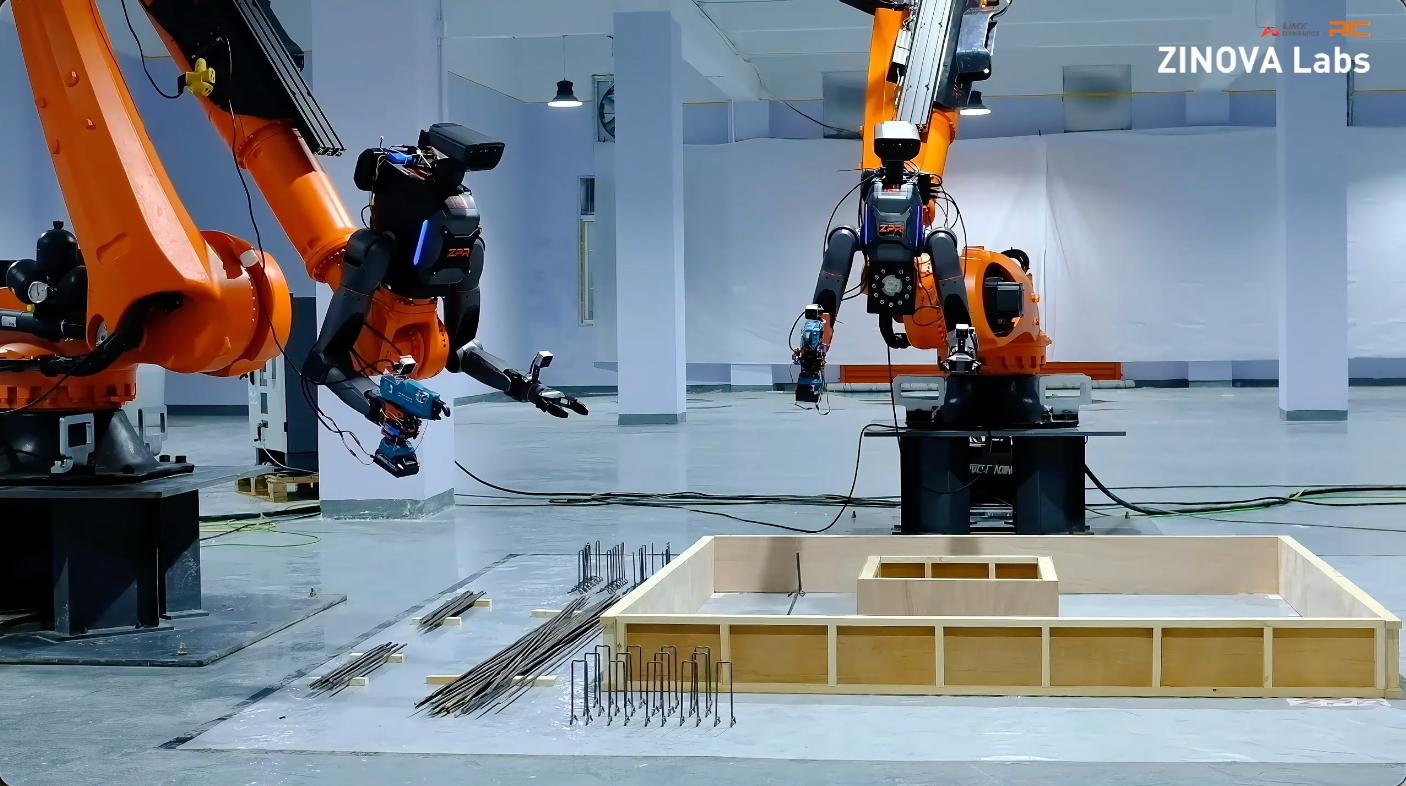
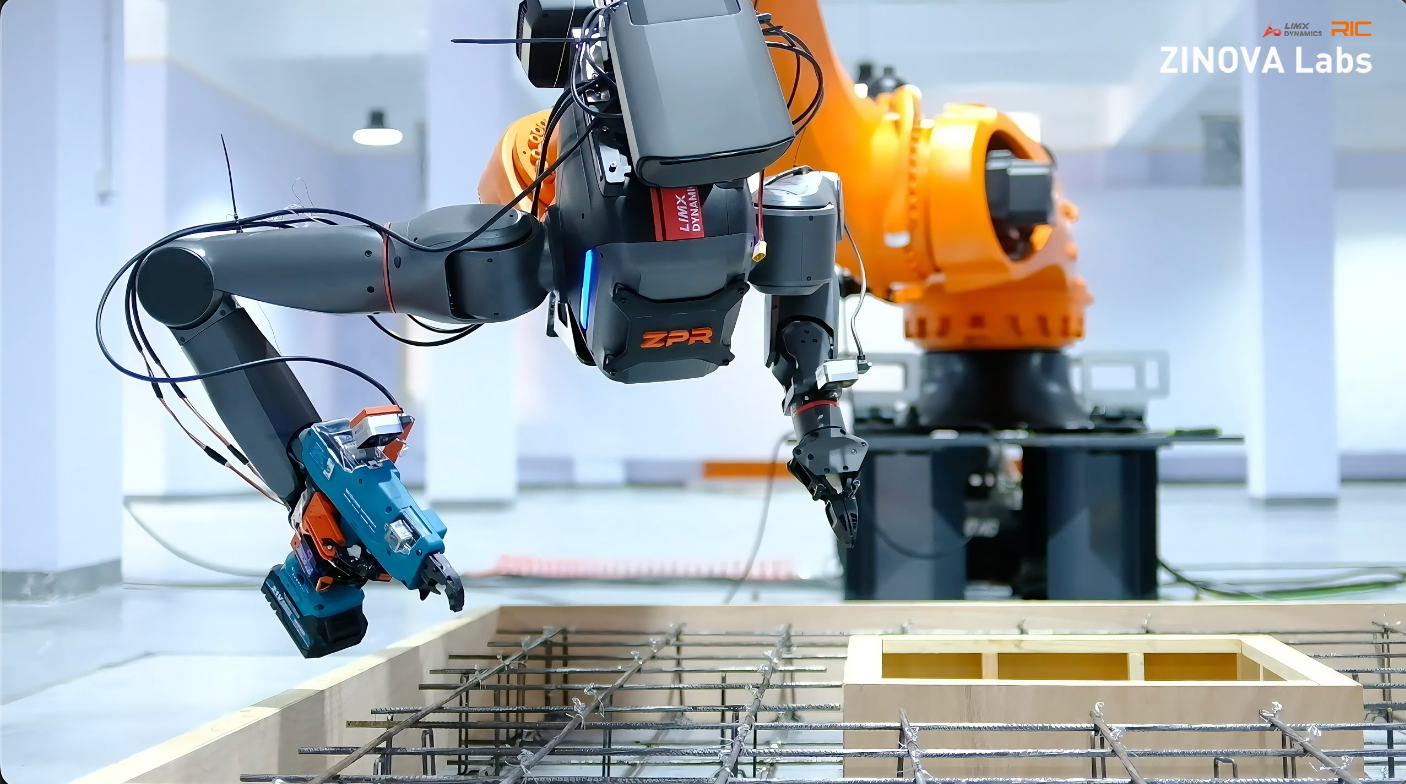
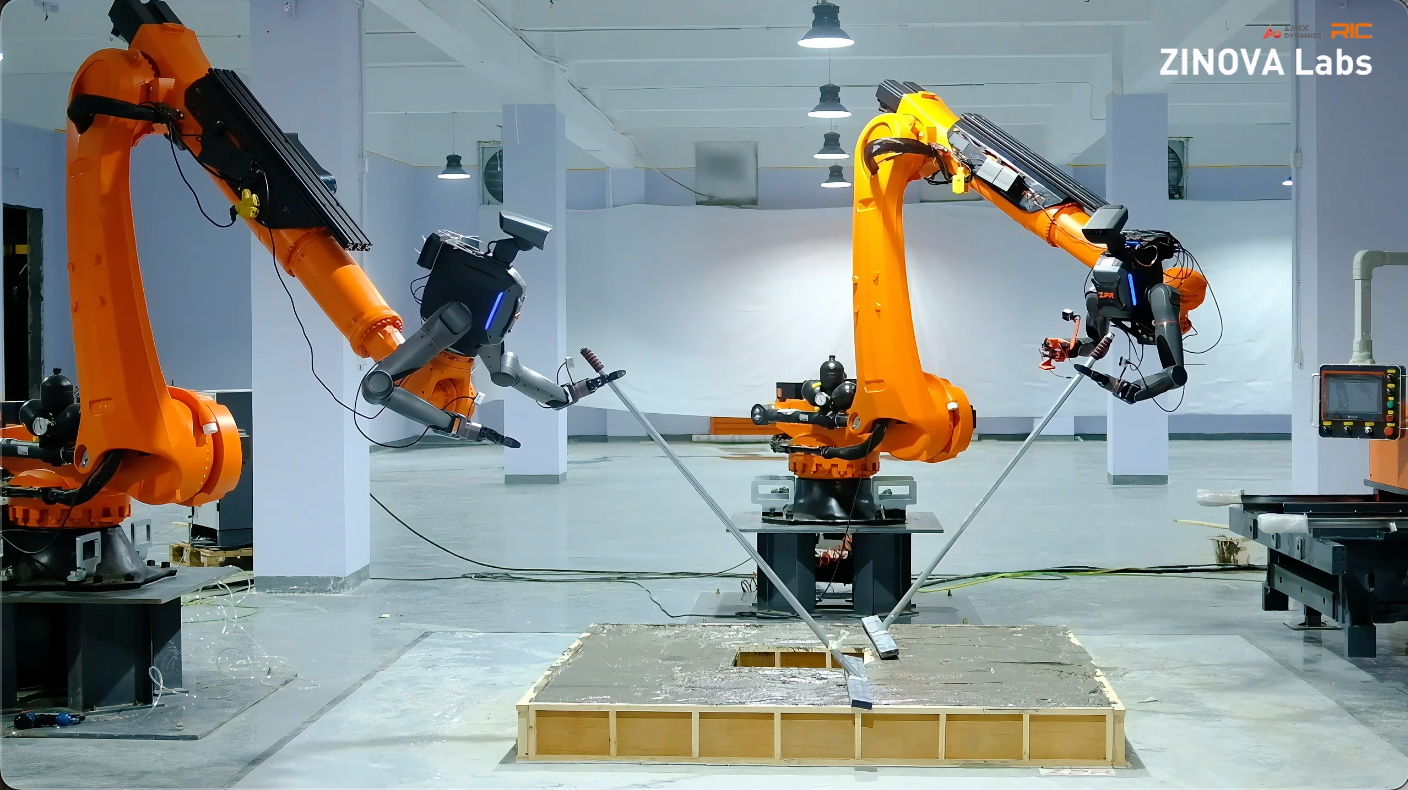
Physical-AI firm ZINOVA, building on LimX Dynamics’ TRON 2 dual-arm embodied robot and with construction-robot company RIC Robotics, completed a scaled demonstration of concrete tilt-up construction, covering formwork framing, multi-layer rebar laying and tying. The proof of concept showed embodied robots can use existing tools to join complex construction flows, and is another original practice of a vertical-industry firm building applications on a general robot platform.
ZINOVA focuses on Tool Intelligence: letting robots recognise, grasp and sense real-world tools to do offline productive work. Its research runs on three axes, Grasp for general tool grasping, Feel for the TEISI sensing interface that captures force, torque, vibration and resistance at the tool-environment contact, and Form for the robot shape suited to a task. Together they form a tool-intelligence system that transfers across tools, tasks and robot forms.
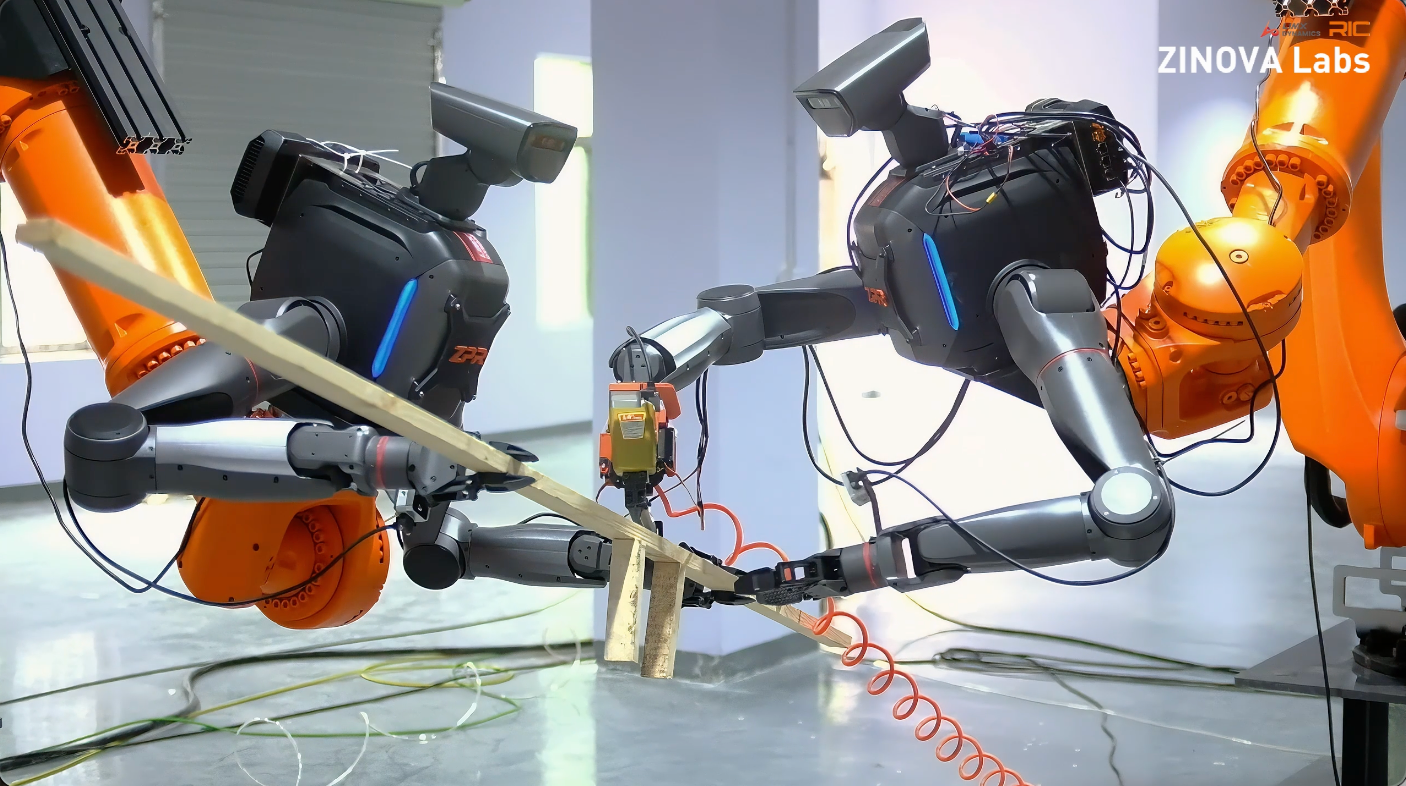
Construction is the first validation scene. The sector faces a chronic skilled-labour constraint, holds vast high-value physical work and a mature tool system, yet every site differs in environment, material and process, resisting one-size-fits-all automation. The demo rebuilt the core tilt-up steps: two TRON 2 robots held a nail gun and timber, cooperating to assemble and fix the formwork, then laid and tied rebar on multi-layer stools, mimicking the sequenced logic of real multi-trade work.
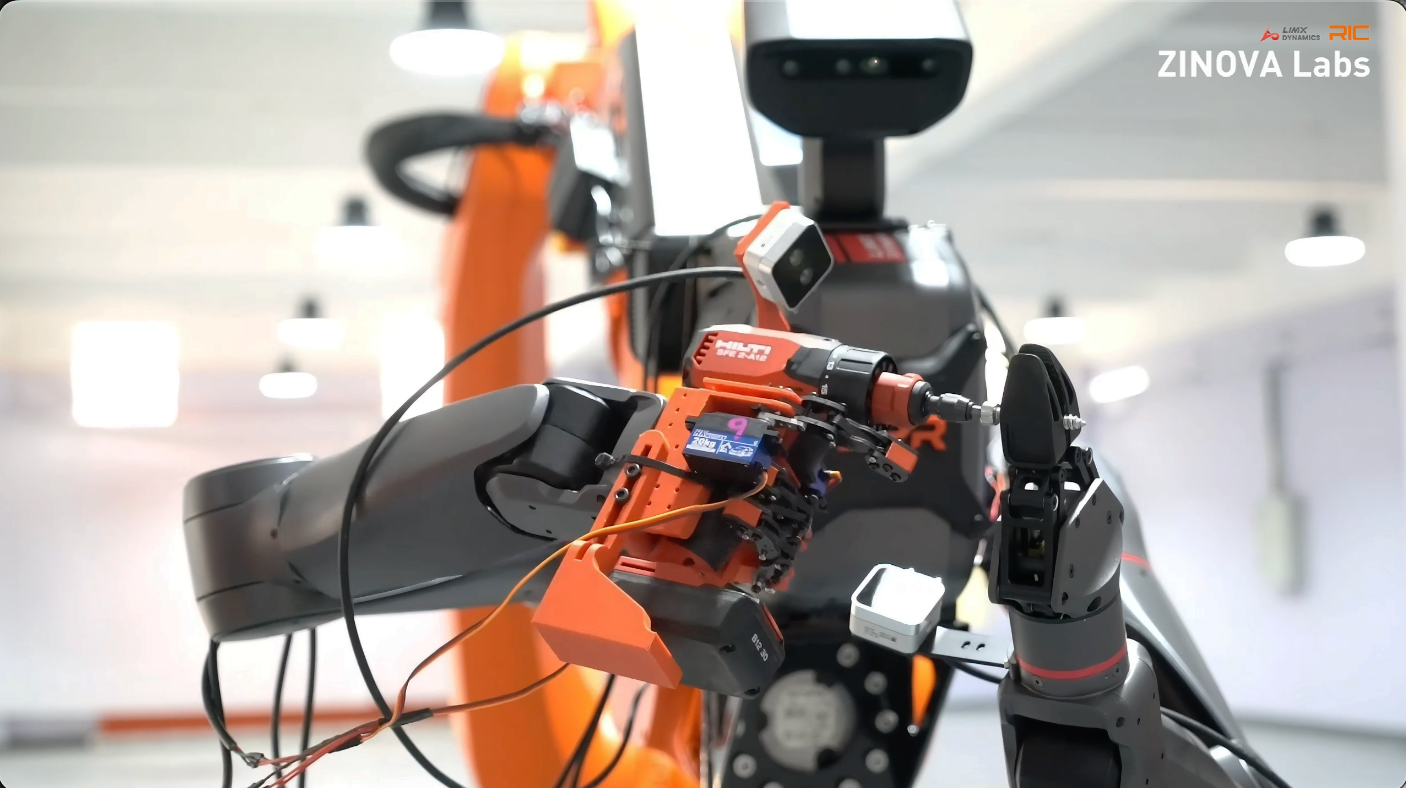
ZINOVA exploited TRON 2’s modular, extensible design to stretch the workspace and tool reach from desktop and low tasks into fuller three-dimensional space, letting both arms operate tools at varied directions and heights. Three ideas shaped the configuration: scenario generality, so one platform swaps tools and bases across processes instead of buying a dedicated robot per job; Human-in-the-Loop, where operators step in at key nodes while every real action feeds data for autonomy; and compliance efficiency, since one robot can cross trade boundaries that today need separate licensed crews.
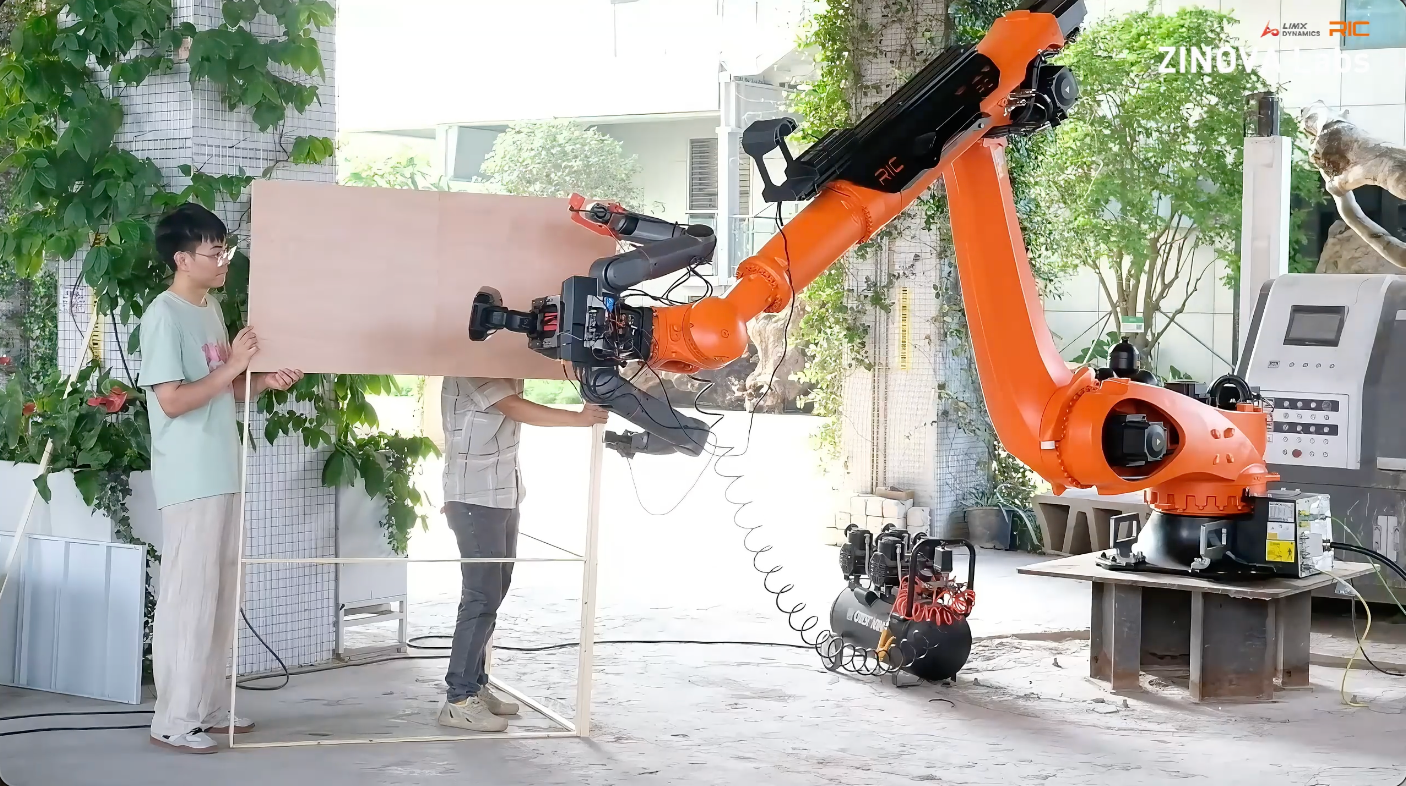
The work reflects LimX Dynamics’ platform strategy: hardware, development-tool and model-training platforms with open SDK, teleoperation interfaces and hardware adapters, so industry innovators build applications on a mature body. TRON 2 is the reusable, extensible general base. ZINOVA founder Xu Ziyou said the breakthrough in physical AI will come not from one robot shape but from intelligence that uses tools across shapes. LimX co-founder Pang Bo said ZINOVA’s depth in construction and focus on tool intelligence are exactly the ecosystem force embodied intelligence needs to land.
From construction, ZINOVA will extend tool intelligence to manufacturing, energy and infrastructure, while LimX keeps building the general robot platform with more industry partners, pushing embodied robots from technology validation toward broader real scenes.
Editor’s note: This is an adapted translation of the original Leiphone (Lingxiang Wang) report. It has been trimmed and restructured for readability for an international business audience. The full original (in Chinese) is at https://www.leiphone.com/category/robot/TaL9FUorWHBFyKzT.html.
Translated and adapted from Leiphone (Lingxiang Wang) (https://www.leiphone.com/category/robot/TaL9FUorWHBFyKzT.html).