BEIJING, 22 August 2026. At the National Speed Skating Oval, the “Ice Ribbon”, the opening of the second World Humanoid Robot Games, state broadcaster CCTV cut to a real tennis court. A humanoid stood at the baseline as a serve arrived above 50 km/h. Within milliseconds it judged the landing, moved its feet, rotated its body and swung. The ball clipped the net tape and dropped in. Across serves, forehands, backhands, baseline rallies and net volleys, it never broke down. In a doubles warm-up it covered for a human partner and changed tactics, and after a spectacular save it fell hard, pushed itself up off the floor and kept playing.
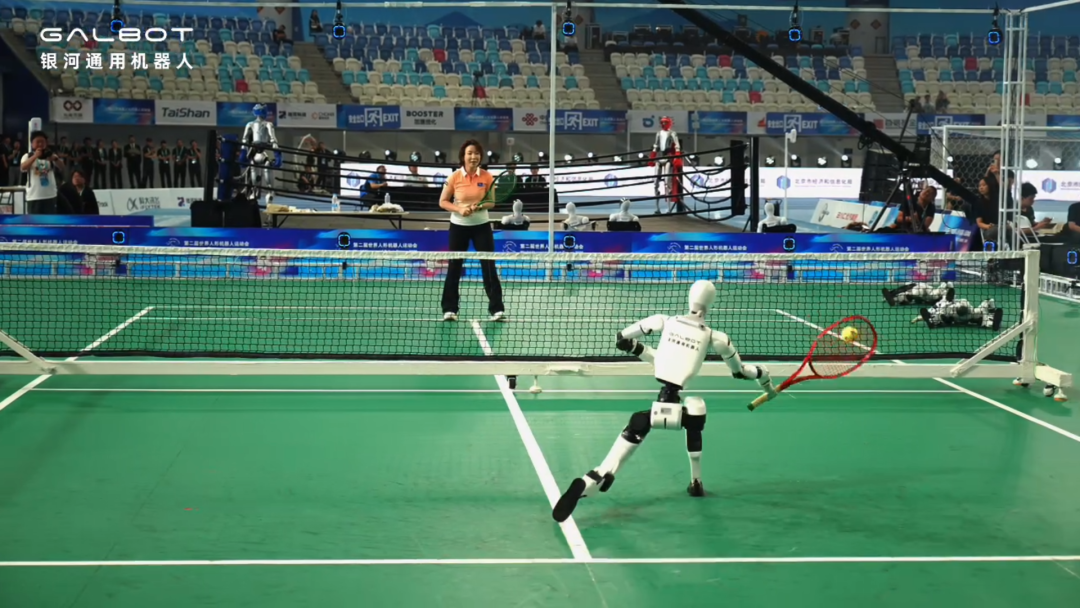
The robot that completed the world’s first fully autonomous tennis rally came from Galbot. A decade ago AlphaGo proved AI could think. Galbot wants to prove AI can act. That shift from thinking to doing took humans ten years, and the company named the moment AstraTennis.
Brain decides how to play, cerebellum plays it beautifully
On court, Galbot’s play looks nothing like the robots of memory. The swing is human-like: feet arrive first, the body drives the arm, upper and lower body fire together, the racket flows, the placement is precise. It is also genuinely general, mastering serves, forehands and backhands, baseline rallies, net play and shot placement, and adjusting tactics in singles, doubles and by format.
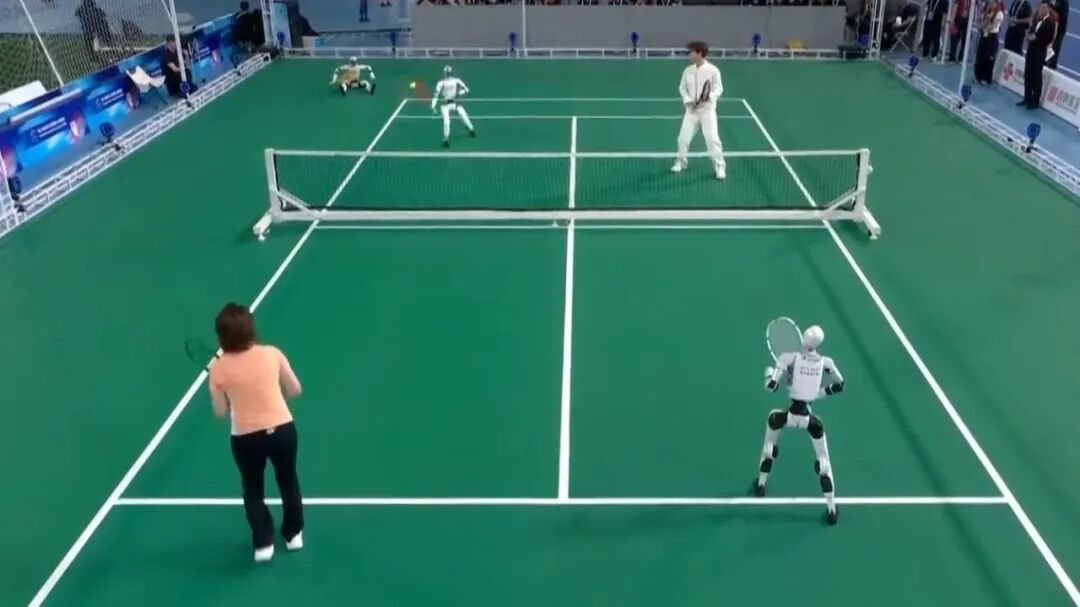
Across the net stood Zheng Jie, a former grand-slam champion. To win a point, the robot had to think about how to win it, not just execute. Galbot’s answer is AstraBrain, an embodied model that welds three jobs into one: the brain for understanding and decision (where the ball lands, how to play, how to cooperate with a doubles partner), the cerebellum for motion control (whole-body balance at speed, explosive swings, human-like movement), and the pons that translates brain decisions into cerebellum commands. This is the claim behind “the world’s first brain-cerebellum-neural integrated whole-body, whole-hand end-to-end model.”
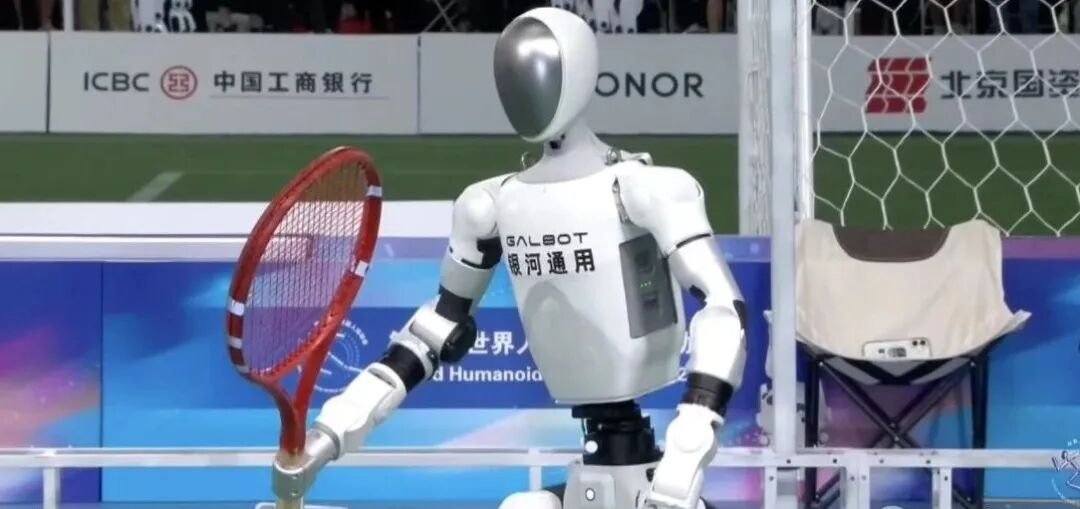
On court the integration shows. A ball arrives, the brain judges in milliseconds whether it is deep or short, attack or defend, while the cerebellum already slides left, crouches and draws the racket back. At contact the brain updates: the last placement was not mean enough, press the line next time. Only a unified architecture can close that think-and-do loop in real time. At CVPR 2026 the team showed AstraBrain-WBC 0.5 reaching 92.58 per cent zero-shot generalisation with sub-1.5-millisecond inference. AstraTennis is that system’s first appearance in realmatches.
Learning from imperfect human data
Galbot founder and CTO Wang He calls tennis the “ultimate exam” for humanoids, because passing it proves you have solved both cerebellum and brain. Teleoperation cannot capture a 50 km/h rally, and motion-capture of a full match is impossibly expensive. So the team built AstraBrain Latent, described as the first full-body real-time planning algorithm for tennis rallying, which mines the latent rules of how to play from fragmentary, imperfect human clips: ordinary people’s forehands, backhands, side steps and cross steps, recomposed and generalised by the algorithm.
A “latent-space action barrier” keeps motions within a human-like envelope while adjusting stance and swing to the incoming ball, and random perturbations during training teach self-correction, so the robot plays a “live ball” that adapts. The value reaches beyond tennis: it lowers the bar to teach robots motor skills at all.
Practising against a thousand selves in a virtual world
Galbot also built its own virtual tennis world on top of Galaxy Star Workshop, a billion-scale embodied dataset. Training runs in two steps: massive pre-play in simulation against virtual opponents of varying skill, then light calibration on the real machine. The key step is multi-agent gaming, where robots play themselves, and abilities no one explicitly taught emerge. Those skills transfer to the real court, which is why AstraTennis appeared in a global livestream rather than a lab video.
Fell, stood up, moved on
The most striking frame was the fall. At speed the robot misjudged aextreme shot, hit the floor, and with no staff rushing in, stood itself up and readied the next return. That detail beats any spec sheet: the motion control is strong enough to recover in the real world’s surprises. Galbot’s path, brain decision, cerebellum execution and data emergence as one, offers the industry a reusable paradigm. A general locomotion base means dance, inspection, rescue and housework can share one “body operating system”, with marginal cost falling as scale rises.
The capability is already running elsewhere. In smart pharmacies a robot picks a target from more than 10,000 items and hands it to a rider. On factory lines, Galbot S1’s dual arms lift 50 kg. Tennis is simply the newest tile it has lit.
Editor’s note: This is an adapted translation of the original Leiphone report. It has been trimmed and restructured for readability for an international business audience.