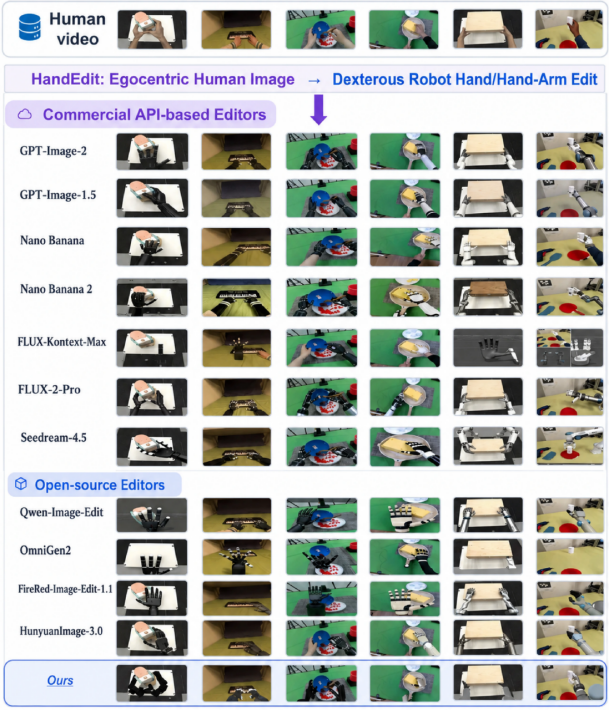
Inshi Robot, with Shanghai Jiao Tong University and Fudan University, has open sourced HandEdit, a dataset and benchmark for first person human to robot dexterous hand image editing. The task keeps the original scene, object, viewpoint and interaction, but swaps the human hand or arm for a specified robot configuration, giving methods paired data, a unified protocol and open tools to train and compare against.
This is not a simple hand swap filter. The edit must fully remove the original hand while holding the object state, contact and background, and the new robot must match the target URDF’s structure, material and joint shape.
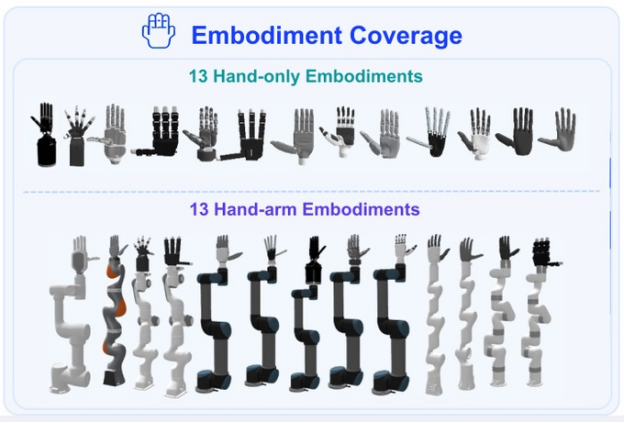
The resources are large. HandEdit offers more than 200 million image edit samples and over 300,000 video clips, drawn from five first person operation datasets, EgoDex, ARCTIC, OakInk2, HOI4D and HO Cap. It covers 26 URDF configurations, 13 standalone dexterous hands and 13 hand arm units, across more than 600 scenes, 1,100 plus objects and 400 plus task types. The 13 hands span brands and structures, including Inshi’s own RH56DFX and RH5DG2, while the hand arm set combines JAKA, KUKA, Panda, RM65 and RM75, UR5 and xArm arms.
The build pipeline runs six steps: segmentation with SAM3 to locate the hand or arm, background repair with ProPainter to fill occluded areas across frames, motion retargeting from MANO or 3D hand pose into the target URDF joint space, arm solving for hand arm data via inverse kinematics, same viewpoint rendering and compositing, and quality screening that drops bad samples. Beyond synthetic images, HandEdit keeps structured robot joint states for checking configuration and correspondence.
Evaluation runs two tracks, Hand only and Hand Arm, each with 1,000 test images, checking visual quality, complete hand removal, correct robot structure and preserved interaction. The point is to let manipulation research train on abundant first person human video and map it onto specific robot bodies without recollecting everything per platform.
Editor’s note: This is an adapted translation of the original OFweek report. It has been trimmed and restructured for readability for an international business audience. The full original (in Chinese) is at https://robot.ofweek.com/2026-09/ART-898890-8120-30701741.html.